About
I am Yu Deng, a Ph.D. candidate in the AI/ML Lab at TU Darmstadt, supervised by Prof. Dr. Kristian Kersting. I am also affiliated with hessian.AI and the JUPITER AI Factory.
My long-term goal is embodied robotic reasoning: building robots that can form explicit, inspectable models of the physical world and their own behavior, test those models through interaction, and use what they learn to act more reliably in changing environments.

Publications
2026
-
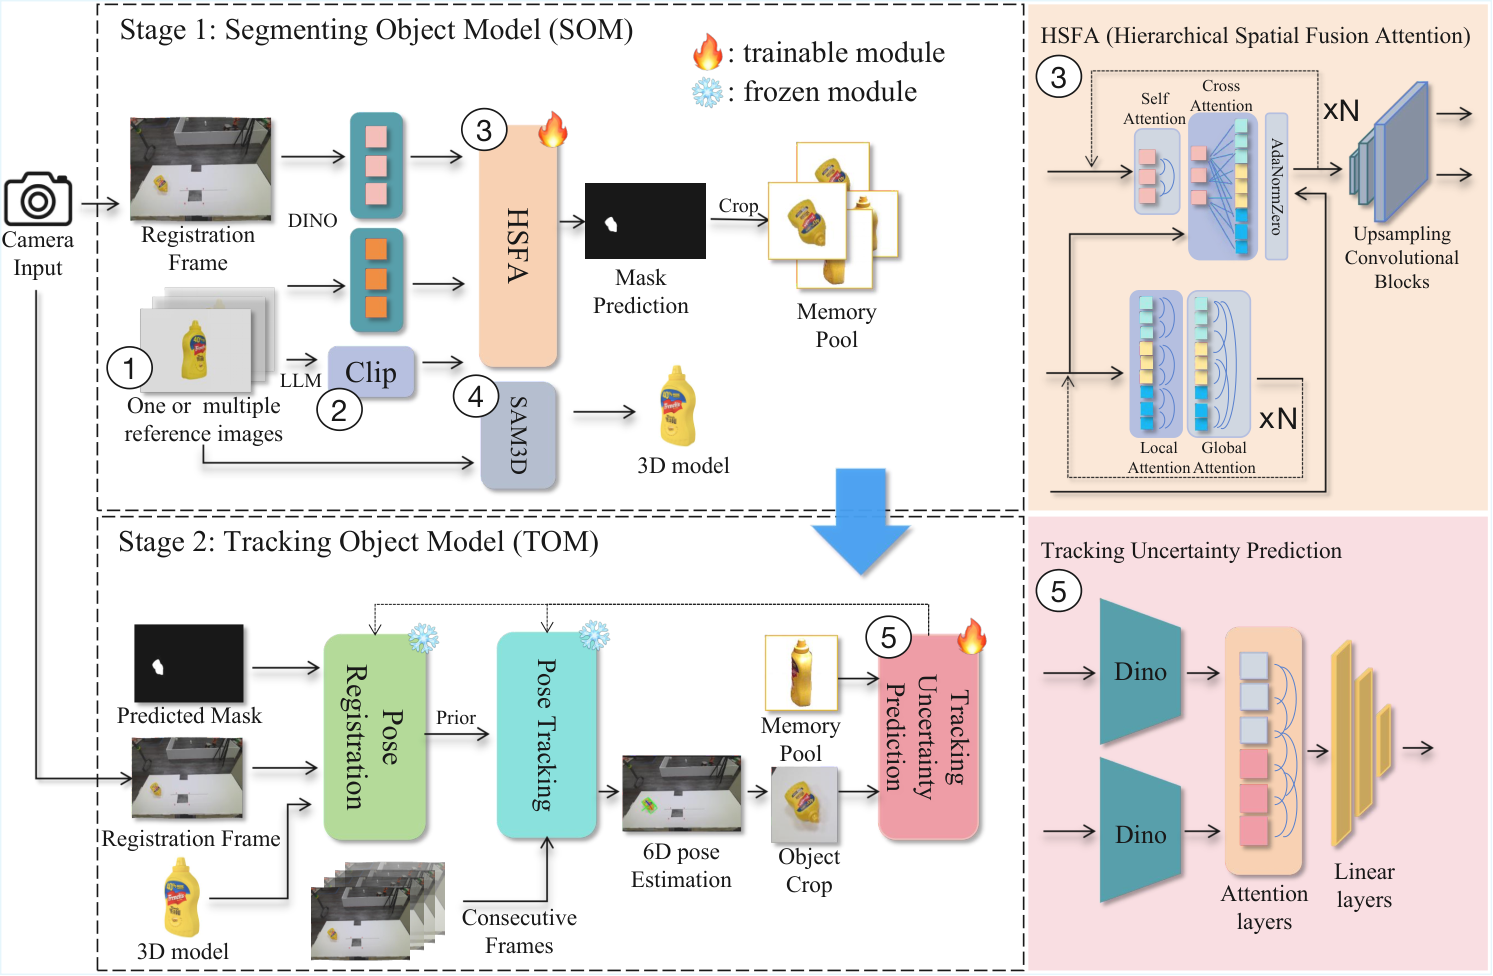
STORM: Segment, Track, and Object Re-Localization from a Single Image
Tracks 6D object pose from a reference image, detects drift, and re-localizes after occlusion or viewpoint changes.
-
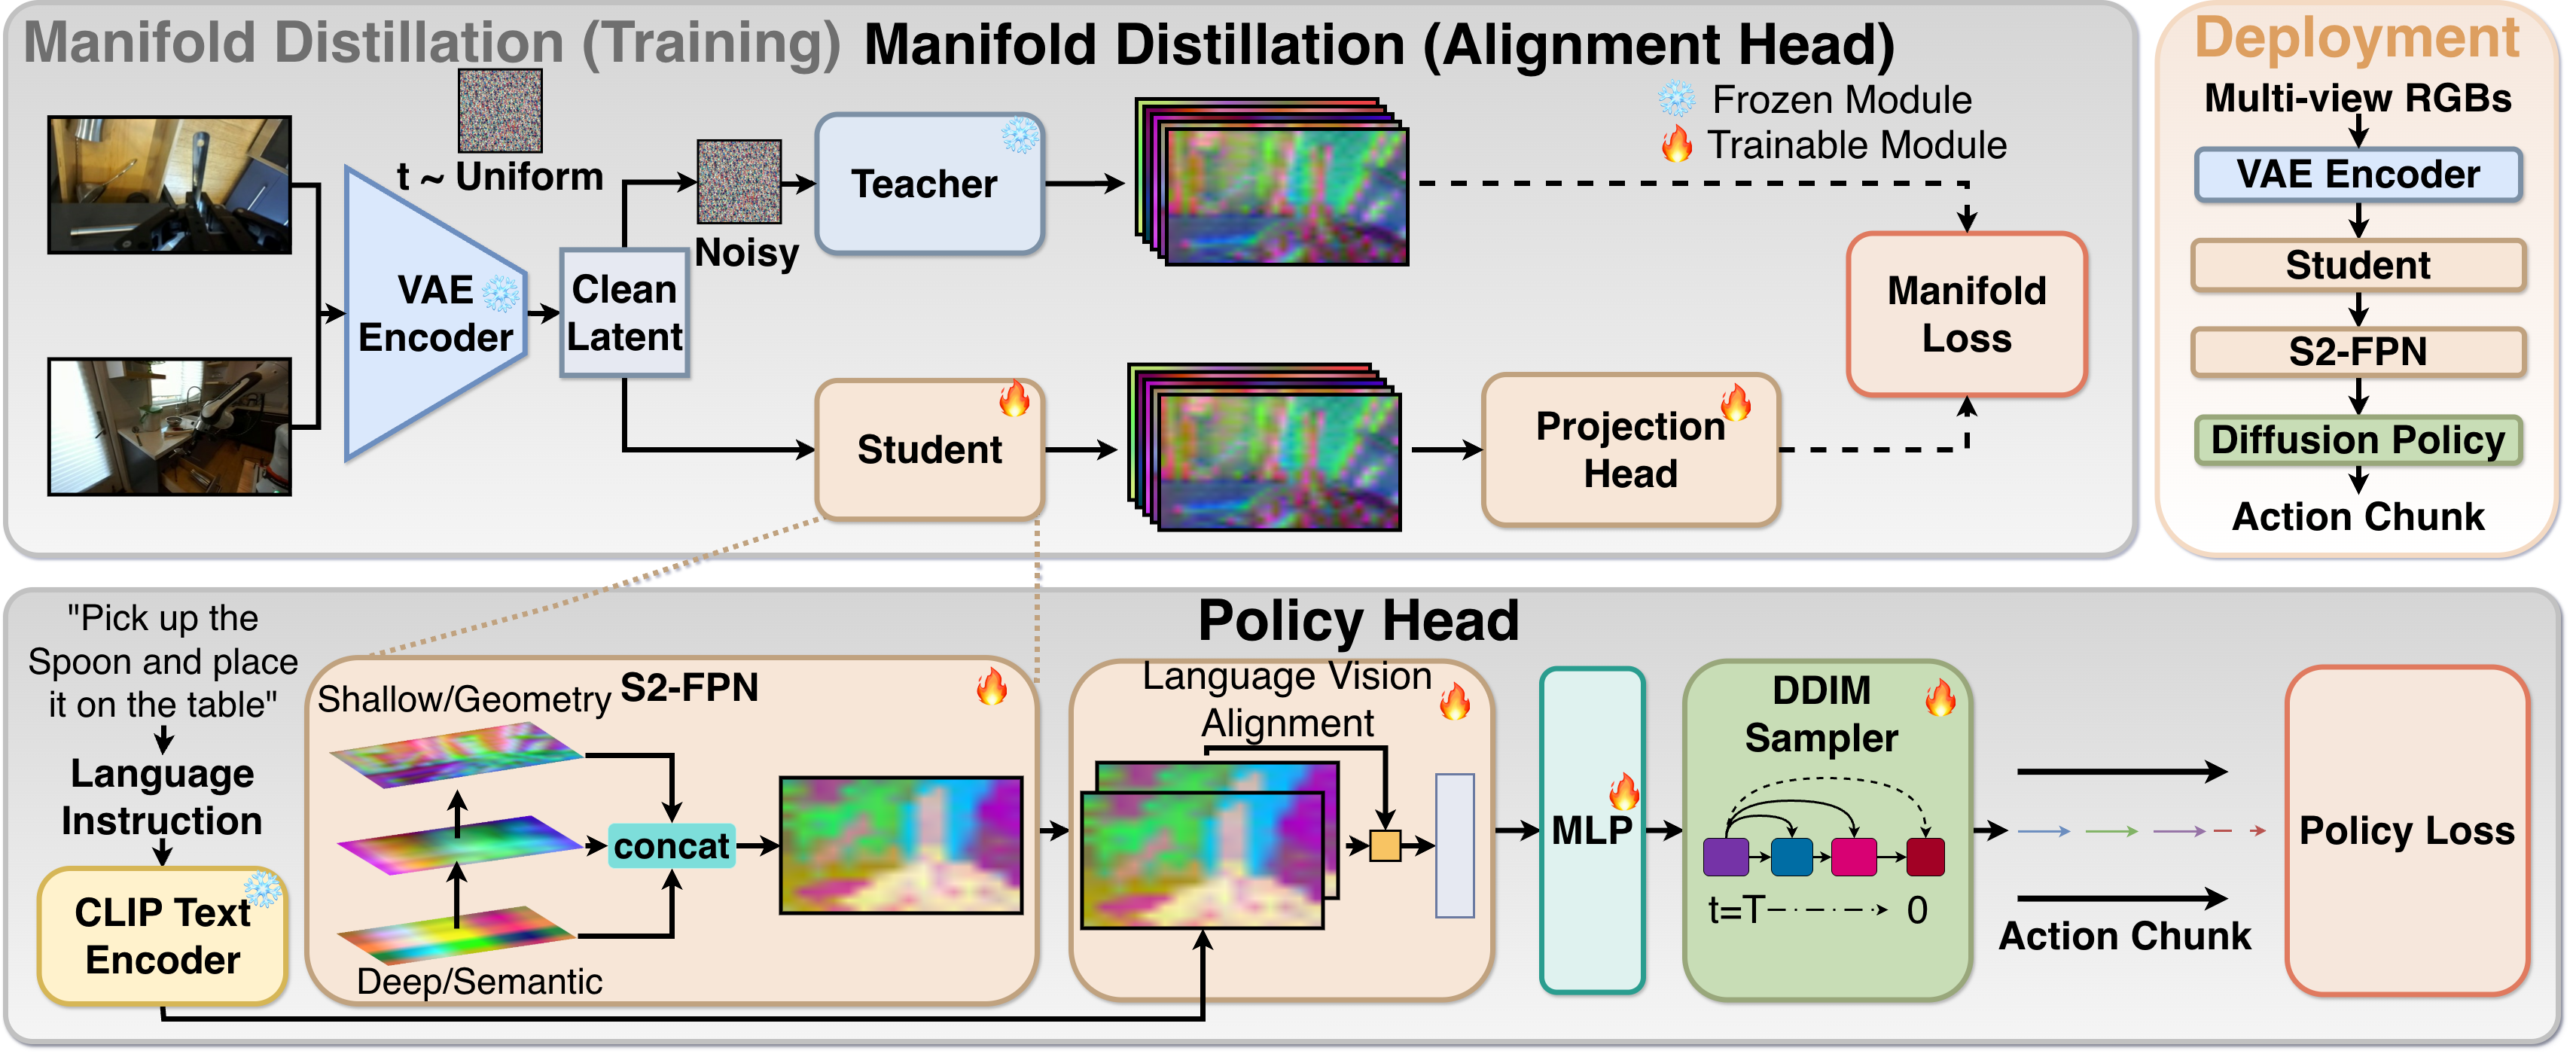
Robot-DIFT: Correspondence-Sensitive Diffusion Features for Contact-Rich Robot Manipulation
Distills diffusion features into a fast visual backbone that preserves geometric correspondences needed for contact-rich control.
-
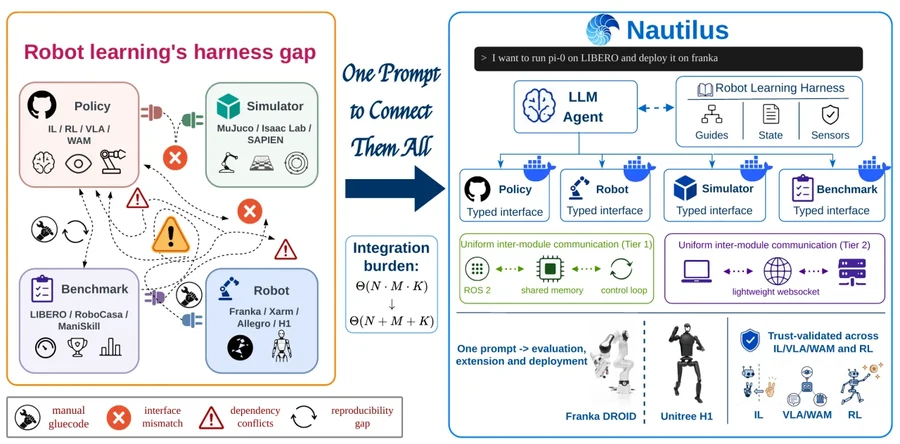
Nautilus: From One Prompt to Plug-and-Play Robot Learning
Turns a single prompt into validated workflows for reproducing, evaluating, fine-tuning, and deploying robot learning methods.
Preprints
-
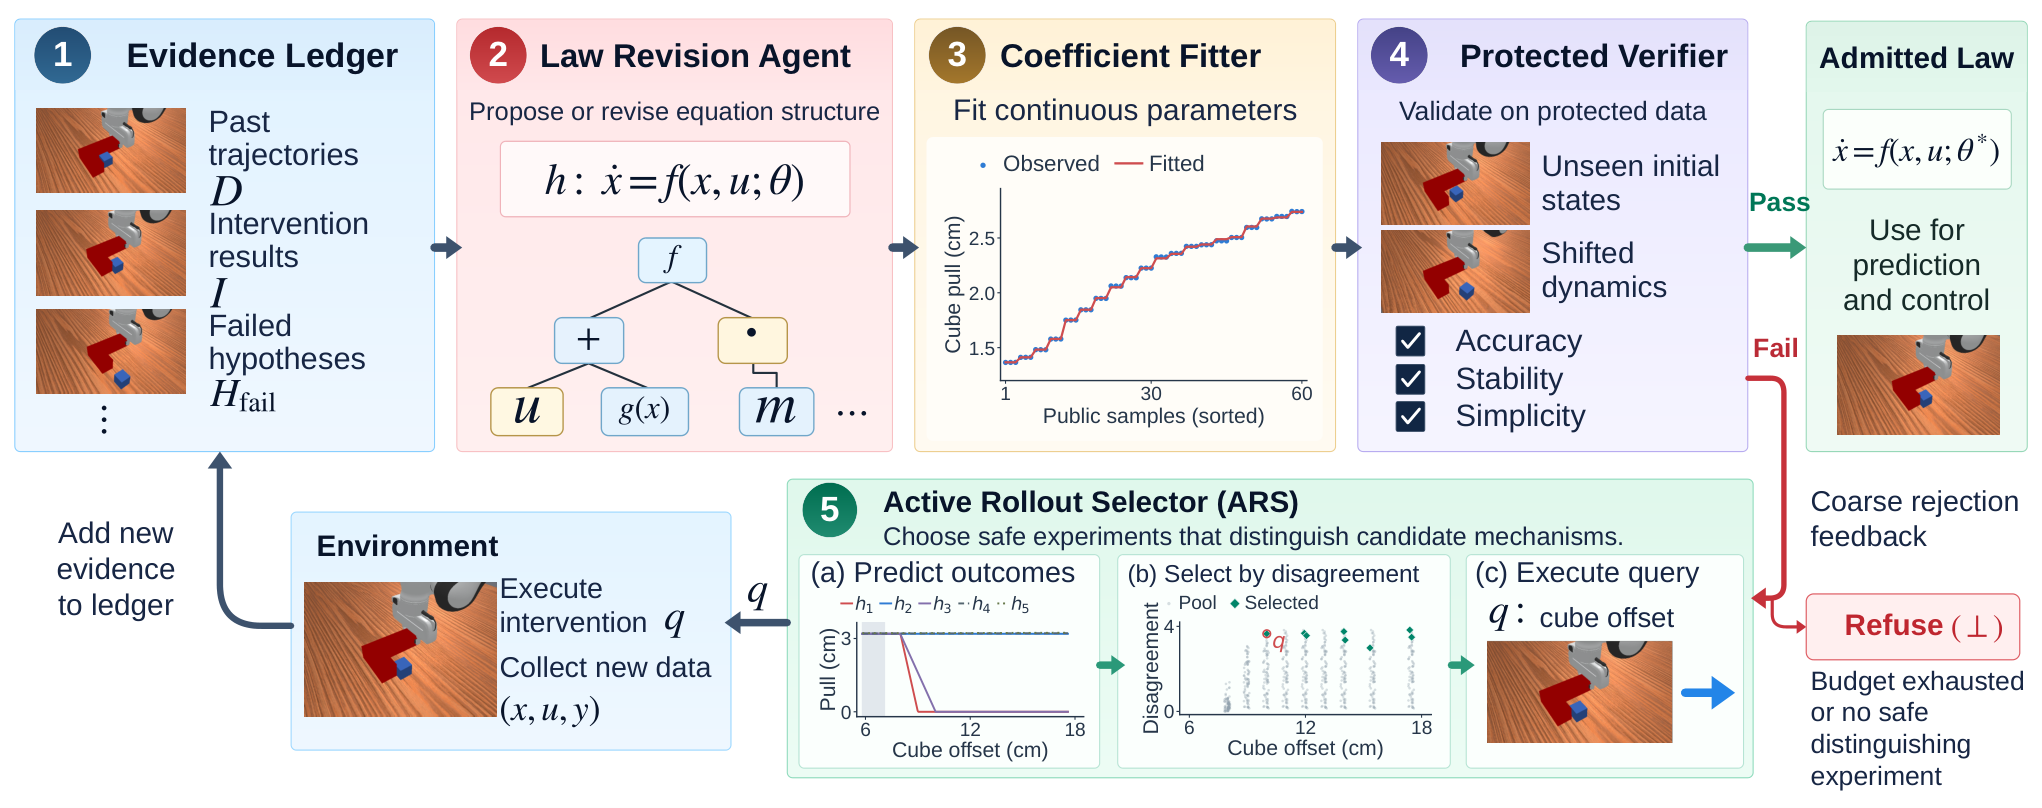
ALDER: Discovering the Laws of a World by Acting in It
Discovers and revises explicit world-model equations through targeted experiments, then uses validated laws for goal-directed control.
-
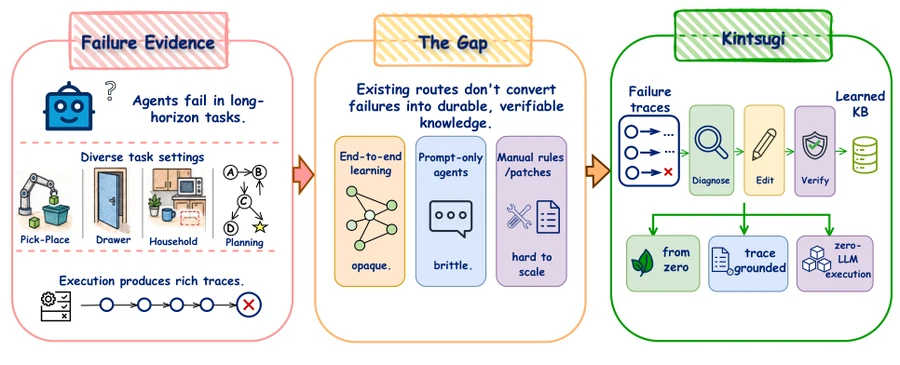
Kintsugi: Learning Policies by Repairing Executable Knowledge Bases
Repairs explicit policy knowledge from rollout failures and admits each edit only after execution and regression checks.
-
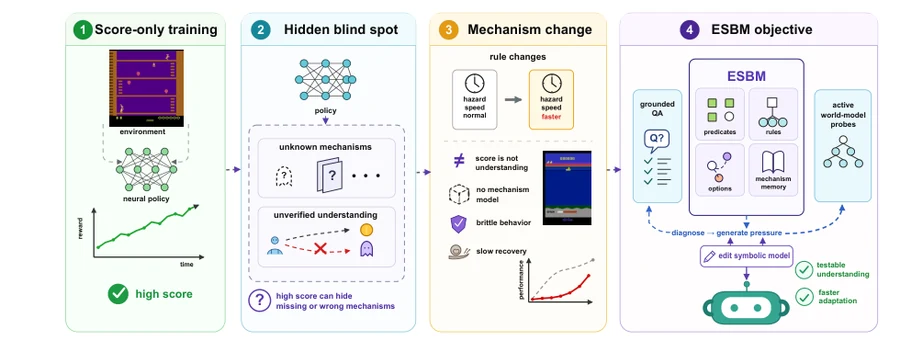
Learning Explicit Behavioral Models with Adaptive Questions and World-Model Probes
Learns inspectable behavioral models through task feedback, adaptive questions, and executable world-model probes.
-
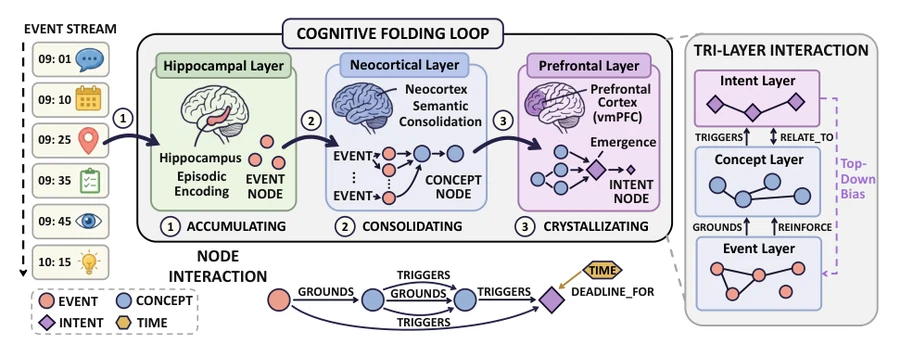
CogniFold: Always-On Proactive Memory via Cognitive Folding
Folds incoming events into evolving memory structures that can surface concepts and intentions for proactive agents.
* Equal contribution.
Education
- Ph.D., TU Darmstadt, since April 2026
- M.Sc., TU Darmstadt, October 2023 – February 2026